



Product Description
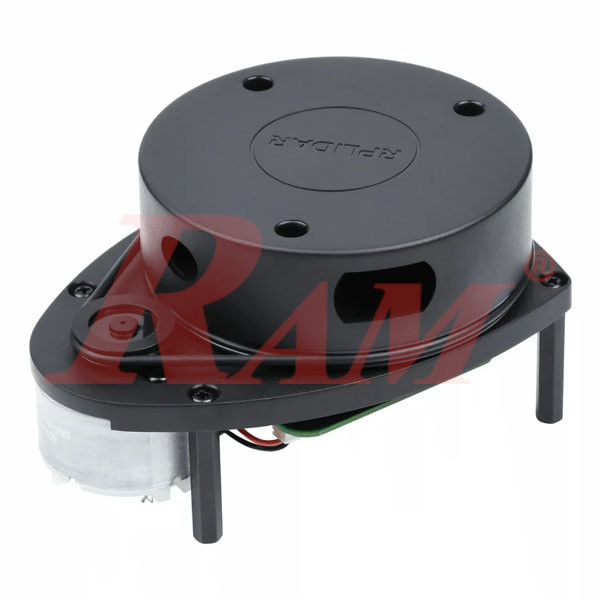
The SLAMTEC RPLIDAR A1M8 is a low-cost 360-degree 2D laser scanning sensor designed for robot navigation, mapping, localization, and environment detection. Using laser triangulation technology, it continuously scans its surroundings and generates 2D point cloud data containing distance and angular measurements.
The RPLIDAR A1M8 provides a typical measurement range of 0.15–12 meters for white objects, with a 360-degree scanning field. It delivers a typical scanning frequency of 5.5Hz and can be configured to reach up to 10Hz. Its laser ranging system performs more than 8,000 measurements per second, enabling detailed environmental scanning and obstacle detection.
The sensor uses a 785nm infrared laser and communicates with external controllers through a 3.3V TTL UART serial interface. Its output data includes measured distance, heading angle, measurement quality, and scan-start information.
The RPLIDAR A1M8 is suitable for autonomous mobile robots, service robots, smart cleaning robots, SLAM applications, obstacle avoidance, and 2D environment mapping.
Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | SLAMTEC |
| Product Model | RPLIDAR A1M8 |
| Sensor Type | 360° 2D Laser Range Scanner (LiDAR) |
| Measurement Technology | Laser Triangulation |
| Typical Measurement Range | 0.15–12m (White Objects) |
| Scanning Angle | 360° |
| Typical Scanning Frequency | 5.5Hz |
| Maximum Scanning Frequency | 10Hz |
| Sample Frequency | ≥8,000Hz (Typical) |
| Maximum Sample Frequency | 8,010Hz |
| Angular Resolution | ≤1° (at 5.5Hz scan rate) |
| Distance Resolution | <1% of measured distance |
| Scan Field Flatness | ±1.5° |
| Laser Wavelength | 785nm (Infrared) |
| Laser Peak Power | 3mW Typical, 5mW Maximum |
| Laser Safety Class | Class I |
| Communication Interface | 3.3V TTL UART |
| Baud Rate | 115200 bps |
| Serial Format | 8N1 |
| Scanner Core Supply Voltage | 5V DC (4.9–5.5V) |
| Motor Supply Voltage | 5–9V DC |
| Scanner Startup Current | 500mA Typical, 600mA Maximum |
| Scanner Operating Current | 300mA Typical, 350mA Maximum |
| Motor Operating Current | 100mA Typical at 5V |
| Operating Temperature | 0°C to +40°C |
| Weight | Approximately 170g |
Technical Information
1. 360-Degree Laser Scanning
The RPLIDAR A1M8 uses a rotating laser scanning mechanism to measure the surrounding environment through a complete 360-degree horizontal scan.
As the scanner rotates, it collects distance measurements at different angles and continuously transmits the resulting data to the host system.
Each measurement point contains:
- Distance: Measured distance between the scanner and the detected object, in millimeters.
- Heading: Measurement angle in degrees.
- Quality: Measurement quality level.
- Start Flag: Indicates the beginning of a new scan.
This information can be processed to generate 2D maps of the surrounding environment.
2. Measurement Range and Performance
The A1M8 provides a typical measurement range of 0.15–12 meters when measuring white objects.
Its measurement performance includes:
- 360-degree scanning coverage.
- Typical scanning frequency of 5.5Hz.
- Configurable scanning frequency up to 10Hz.
- Measurement sampling frequency of at least 8,000Hz.
- Angular resolution of ≤1° at a 5.5Hz scanning rate.
- Distance resolution of less than 1% of the measured distance.
Actual detection performance may vary depending on the target object's color, surface properties, reflectivity, and environmental conditions.
3. Laser Triangulation Technology
The RPLIDAR A1M8 operates using laser triangulation technology.
It emits a modulated infrared laser signal toward surrounding objects. The reflected signal is captured by the internal optical acquisition system and processed by the onboard digital signal processor (DSP).
The system calculates the distance and angle of each detected point and transmits the resulting measurement data through its communication interface.
The ranging system performs more than 8,000 measurements per second.
4. UART Communication Interface
The RPLIDAR A1M8 communicates with external systems through a 3.3V TTL UART serial interface.
Communication specifications:
- Baud rate: 115200 bps.
- Data format: 8N1.
- Logic high output: 2.9–3.5V.
- Logic low output: 0–0.4V.
The serial interface allows integration with embedded systems and compatible development platforms.
5. Separate Power Supply for Scanner and Motor
The RPLIDAR A1M8 has two separate power systems:
Scanner System
- Supply voltage: 4.9–5.5V DC.
- Recommended nominal voltage: 5V DC.
- Typical operating current: 300mA.
- Maximum operating current: 350mA.
- Startup current: 500mA typical, up to 600mA.
Motor System
- Supply voltage: 5–9V DC.
- Typical current: 100mA at 5V.
- Motor voltage can be adjusted to control scanning speed.
The manufacturer recommends powering the scanner and motor systems separately to ensure measurement accuracy.
For scanning frequencies above 5.5Hz, up to 10Hz, a separate 9V supply should be provided to the motor system.
6. Laser Safety and Environmental Conditions
The A1M8 uses a low-power infrared laser with a typical peak power of 3mW and a maximum specified peak power of 5mW.
It complies with Class I laser safety requirements according to the datasheet.
The modulated laser signal helps reduce the effects of ambient light, allowing the sensor to operate in various indoor environments and outdoor environments without direct sunlight exposure.
The specified operating temperature range is 0°C to +40°C.
Features
- 360-degree horizontal laser scanning.
- Typical measurement range of 0.15–12 meters for white objects.
- Laser triangulation measurement technology.
- Typical scanning frequency of 5.5Hz.
- Configurable scanning frequency up to 10Hz.
- Sampling frequency of at least 8,000 measurements per second.
- Angular resolution of ≤1° at 5.5Hz.
- 785nm infrared laser.
- Class I laser safety classification.
- 3.3V TTL UART communication.
- Continuous 2D point cloud data output.
- Separate scanner and motor power systems.
- Compatible with robotics and SLAM development platforms.
Applications
- Autonomous mobile robot navigation.
- Simultaneous Localization and Mapping (SLAM).
- Robot positioning and localization.
- Obstacle detection and avoidance.
- Home service and cleaning robots.
- Industrial mobile robotics.
- Smart toys and robotic navigation projects.
- Indoor environment scanning.
- 2D mapping and environmental modeling.
- Robotics research and educational development.
Frequently Asked Questions (FAQ)
1. What is the RPLIDAR A1M8?
The RPLIDAR A1M8 is a 360-degree 2D laser scanning sensor developed by SLAMTEC. It measures distances to surrounding objects and generates point cloud data for mapping, localization, and robot navigation.
2. What is the maximum measurement range of the A1M8?
The typical measurement range is 0.15–12 meters when measuring white objects. Actual performance depends on the target surface and environmental conditions.
3. Does the RPLIDAR A1M8 provide a full 360-degree scan?
Yes. Its rotating scanning mechanism continuously measures the surrounding environment across a complete 360-degree horizontal field.
4. What is the scanning frequency of the A1M8?
The typical scanning frequency is 5.5Hz, and it can be configured up to 10Hz. When operating above 5.5Hz, the motor requires a separate 9V power supply.
5. How does the RPLIDAR A1M8 communicate with a microcontroller?
It uses a 3.3V TTL UART serial interface with a standard baud rate of 115200 bps and an 8N1 communication format.
6. Is the RPLIDAR A1M8 compatible with Arduino and Raspberry Pi?
The sensor provides a standard UART interface that can be integrated with compatible embedded systems. The host controller must support the required serial communication and power requirements. SLAMTEC also provides SDK support for Windows x86, Linux x86, and ARM Linux platforms.
7. Can the RPLIDAR A1M8 be used outdoors?
It can operate in outdoor environments without direct sunlight exposure. However, the manufacturer does not recommend operation under direct sunlight because environmental lighting can affect measurement performance.
8. Does the RPLIDAR A1M8 require separate power supplies for the motor and scanner?
Yes. The scanner core requires a regulated 5V supply (4.9–5.5V), while the motor requires 5–9V. The manufacturer recommends supplying these systems separately. A separate 9V motor supply is required when configuring scanning frequencies above 5.5Hz.
Download: